1.7 Joint Motion Range Description (Warranted)
Angle values in the tables below are rounded to the nearest 0.5°. The sign of an angle indicates the rotation direction of the joint about the corresponding axis. The positive direction is determined by the right-hand rule: point the thumb of the right hand along the positive direction of the axis, and the fingers curl in the positive (angle-increasing) direction.
The Roll / Pitch / Yaw in each joint name correspond to the three rotation axes of the robot’s body coordinate system:
Roll: rotation about the X axis, corresponding to lateral (roll) motion
Pitch: rotation about the Y axis, corresponding to forward/backward (pitch) motion
Yaw: rotation about the Z axis, corresponding to horizontal (yaw) motion
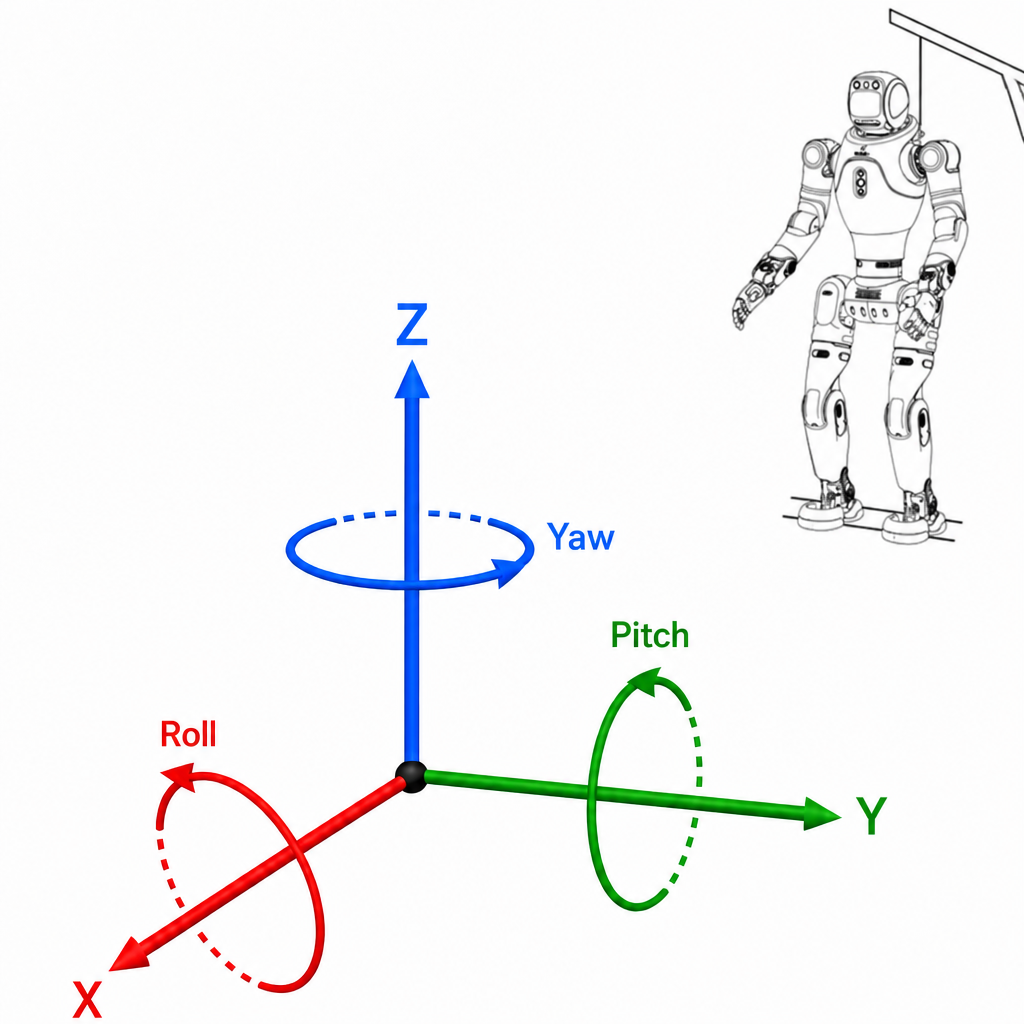
Robot coordinate system diagram (X axis forward, Y axis left, Z axis up, positive rotation directions determined by the right-hand rule)
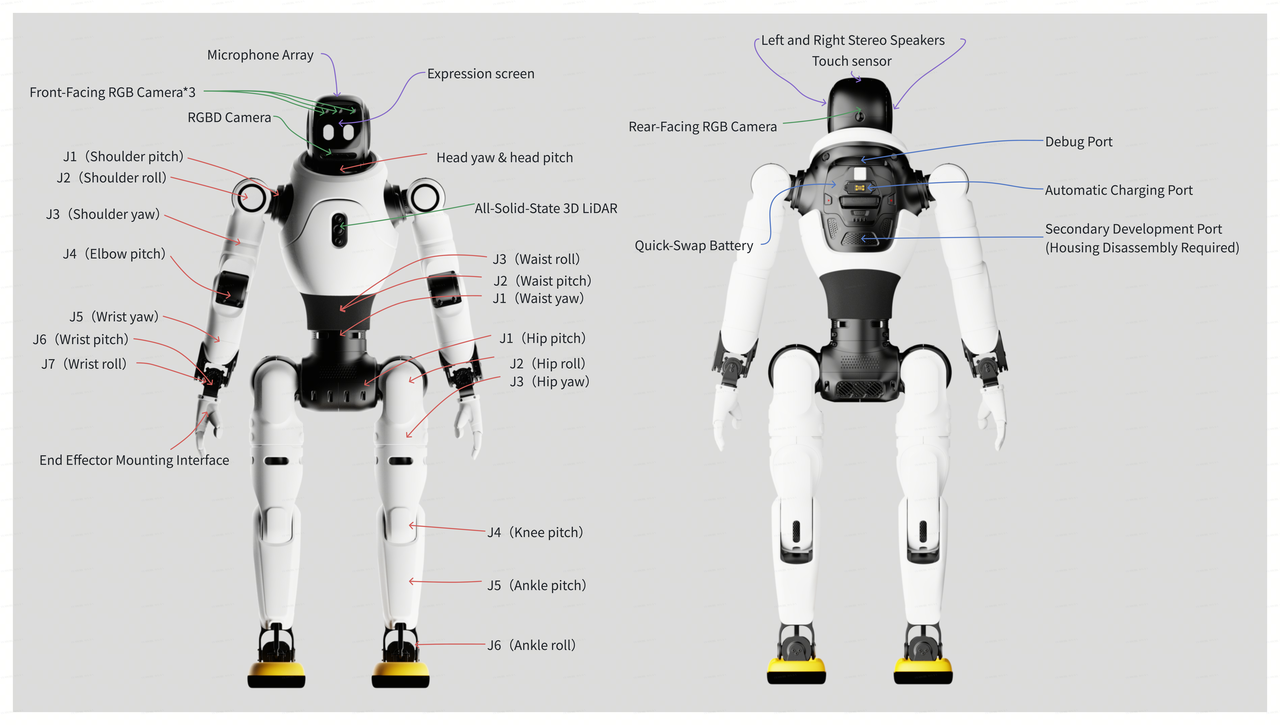
Joint Naming Diagram
1.7.1 Arm Motion Range
Joint Name |
X2 Ultra Edition |
X2 Ultra(new version) |
X2 EDU |
|---|---|---|---|
J1 (Shoulder pitch) |
-176.5° ~ +116.5° |
-176.5° ~ +116.5° |
-176.5° ~ +116.5° |
J2 (Shoulder roll) |
-3.5° ~ +174.5° |
-3.5° ~ +174.5° |
-3.5° ~ +174.5° |
J3 (Shoulder yaw) |
±146.5° |
±146.5° |
±146.5° |
J4 (Elbow) |
-135° ~ 0° |
-135° ~ 0° |
-135° ~ 0° |
J5 (Wrist yaw) |
±146.5° |
±146.5° |
±146.5° |
J6 (Wrist pitch) |
±30° |
±30° |
±30° |
J7 (Wrist roll) |
-86.5° ~ +41.5° |
-86.5° ~ +41.5° |
-86.5° ~ +41.5° |
1.7.2 Leg Motion Range
Joint Name |
X2 Ultra Edition |
X2 Ultra(new version) |
X2 EDU |
|---|---|---|---|
J1 (Hip pitch) |
-155° ~ +146.5° |
-155° ~ +146.5° |
-155° ~ +146.5° |
J2 (Hip roll) |
-13.5° ~ +166.5° |
-13.5° ~ +166.5° |
-13.5° ~ +166.5° |
J3_Left (Hip yaw) |
-106.5° ~ +206.5° |
-106.5° ~ +206.5° |
-106.5° ~ +206.5° |
J3_Right (Hip yaw) |
-206.5° ~ +106.5° |
-206.5° ~ +106.5° |
-206.5° ~ +106.5° |
J4 (Knee) |
0° ~ +138° |
0° ~ +138° |
0° ~ +138° |
J5 (Ankle pitch) |
-46° ~ +26° |
-46° ~ +26° |
-46° ~ +26° |
J6 (Ankle roll) |
±17° |
±15° |
±15° |
1.7.3 Head Motion Range
Joint Name |
X2 Ultra Edition |
X2 Ultra(new version) |
X2 EDU |
|---|---|---|---|
J1 (Head yaw) |
±20° |
±28° |
N/A |
J2 (Head pitch) |
N/A |
-23° ~ +28° |
N/A |
1.7.4 Waist Motion Range
Joint Name |
X2 Ultra Edition |
X2 Ultra(new version) |
X2 EDU |
|---|---|---|---|
J1 (Waist yaw) |
-196.5° ~ +126.5° |
-196.5° ~ +121.5° |
-196.5° ~ +121.5° |
J2 (Waist pitch) |
±18° |
±18° |
±18° |
J3 (Waist roll) |
±28° |
±28° |
±28° |